Dense reconstruction and planar rooms
Rooms reconstructed densely from capture, then decomposed into planar surfaces — floors, walls and openings — so a scene becomes a compact set of geometric primitives instead of a raw mesh.
3D vision · neural rendering · SLAM
I work on the parts of computer vision that turn cameras into 3D: dense reconstruction, neural rendering, and real-time SLAM.
Most recently I was a Computer Vision Research Scientist at Simulon, building the capture-to-asset pipeline behind the app — photometric capture, monocular and LiDAR reconstruction, 3D Gaussian Splatting, and real-time splat rendering on device and web. Before that, five years at Slamcore in London on visual-inertial SLAM and long-term mapping, and a PhD at Clermont Auvergne on light-source modelling, specularity and diminished reality.
Paris · Hybrid

Gaussian splat · drag to turn
Rooms reconstructed densely from capture, then decomposed into planar surfaces — floors, walls and openings — so a scene becomes a compact set of geometric primitives instead of a raw mesh.
A dense photometric SLAM system for handheld phone video: camera tracking and a dense point map built progressively as the capture plays, then used to initialise 3D Gaussian Splatting — shown as point map, then splat geometry, then the final render.
Complete, textured 3D meshes recovered from just a handful of photographs — sparse-view surface reconstruction for scenes where a full capture isn’t practical.
Everyday objects captured as images and turned into Gaussian-splat assets in under a minute, rendered in real time on device and web — the asset pipeline behind the app.
Real-time visual-inertial mapping on a handheld sensor: pose tracking, dense surface reconstruction and loop closure. The small inset is the live camera feed; the coloured surface is the map built from it.
2023 — 2026
Photometric capture, dense reconstruction and neural rendering for a mobile 3D capture app. Contracted through my own research company.
2018 — 2023
Visual-inertial odometry, long-term and multi-session mapping, panoptic segmentation for intelligent mapping, and the accuracy metrics behind QA.
2014 — 2018
Augmented-reality realism: light-source modelling, specularity prediction, inpainting and diminished reality in real time. Supervised by Adrien Bartoli and Mohamed Tamaazousti.
2011 — 2014
Fiducial-marker detection and constrained SLAM; real-time 3D localisation for self-driving vehicles.
A Geometric Model for Specularity Prediction on Planar Surfaces with Multiple Light Sources
A. Morgand, M. Tamaazousti, A. Bartoli
A Multiple-View Geometric Model of Specularities on Non-Planar Shapes with Application to Dynamic Retexturing
A. Morgand, M. Tamaazousti, A. Bartoli
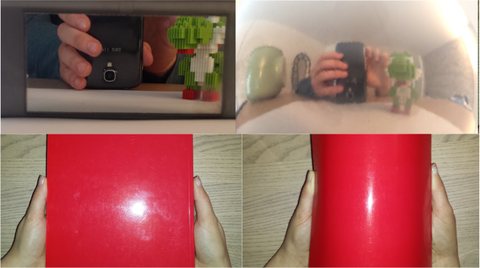
A Multiple-View Geometric Model of Specularities on Non-Uniformly Curved Surfaces
A. Morgand, M. Tamaazousti, A. Bartoli
An Empirical Model for Specularity Prediction with Application to Dynamic Retexturing
A. Morgand, M. Tamaazousti, A. Bartoli
Generic and Real-time Detection of Specular Reflections in Images
A. Morgand, M. Tamaazousti
13 papers in total · Full list on Google Scholar →
2023
Visual-Inertial Localisation in an Existing Map
P. Alcantarilla, A. Morgand, M. Boucher · US 11,830,218 B2 — Slamcore Ltd
2022
Visual-Inertial Localisation in an Existing Map
P. Alcantarilla, A. Morgand, M. Boucher · GB 2 599 947 B — Slamcore Ltd
2019
Method for Processing Images Having Specularities and Corresponding Computer Program Product
M. Tamaazousti, A. Morgand, A. Bartoli · US 10,497,136 B2 — CEA